|
Guillaume Bellegarda I am a Research Scientist (ISFP) at Inria in Nancy, France. I am broadly interested in learning and control for dynamic robots. Previously, I was a postdoctoral researcher at EPFL with Auke Ijspeert and at University of Southern California with Quan Nguyen. I received my PhD from UC Santa Barbara, advised by Katie Byl, and my bachelor's degree from UC Berkeley. |
|
Publications |
|
Learning diverse and efficient rhythmic locomotion skills for humanoids
Guillaume Bellegarda under review, 2027 arXiv (coming soon) / project page (coming soon) / video (coming soon) |
|
|
Learning optimal gaits and styles for terrain-adaptive quadruped locomotion
Guillaume Bellegarda, Auke Ijspeert preprint, 2026 arXiv / project page / video (coming soon) |
|
|
Energy efficiency and neural control of continuous versus intermittent swimming in a fishlike robot
Xiangxiao Liu, François A. Longchamp, Luca Zunino, Louis Gevers, Lisa R. Schneider, Selina I. Bothner, André Guignard, Alessandro Crespi, Guillaume Bellegarda, Alexandre Bernardino, Eva A. Naumann, Auke J. Ijspeert Science Robotics, 2026 paper |
|
|
AllGaits: Learning all quadruped gaits and transitions
Guillaume Bellegarda, Milad Shafiee, Auke Ijspeert IEEE International Conference on Robotics and Automation (ICRA), 2025 arXiv / paper / video |
|
|
SATA: Safe and adaptive torque-based locomotion policies inspired by animal learning
Peizhuo Li, Hongyi Li, Ge Sun, Jin Cheng, Xinrong Yang, Guillaume Bellegarda, Milad Shafiee, Yuhong Cao, Auke Ijspeert, Guillaume Sartoretti Robotics: Science and Systems, 2025 arXiv / paper / video |
|
|
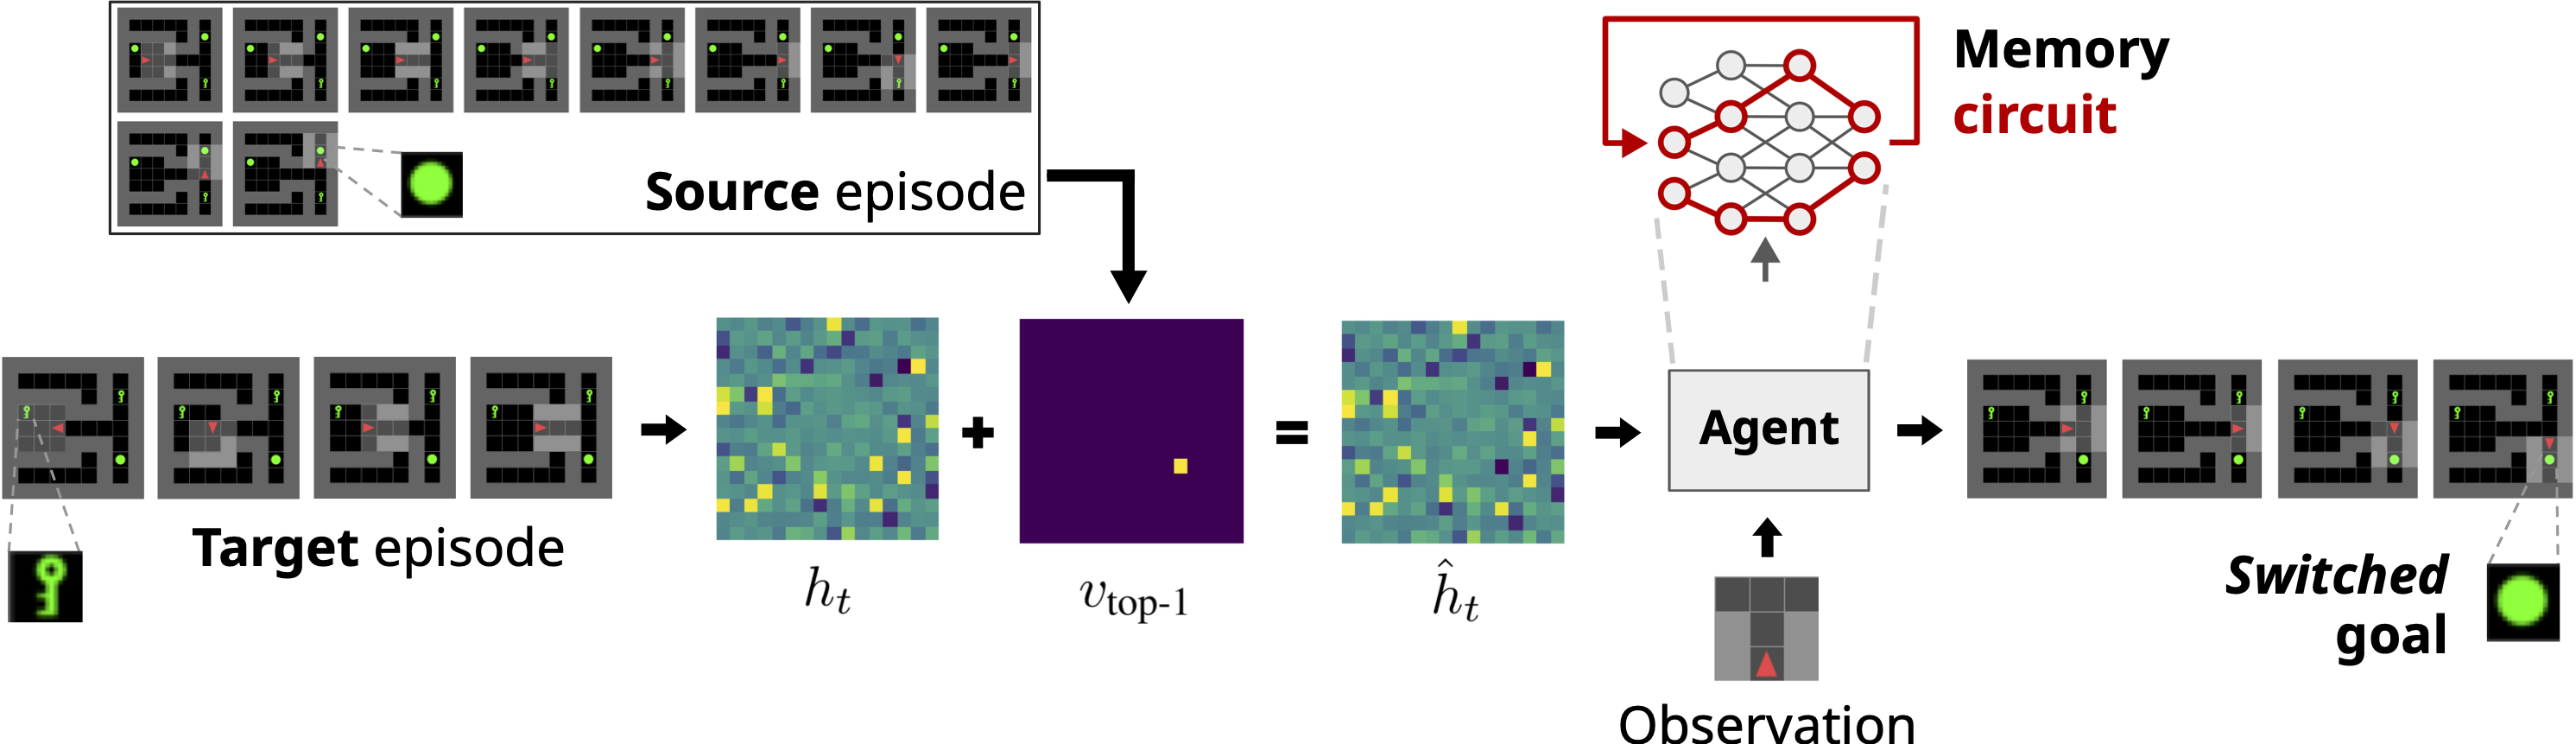
Reverse-Engineering Memory in DreamerV3: From Sparse Representations to Functional Circuits
Jan Sobotka, Auke Ijspeert, Guillaume Bellegarda NeurIPS Mechanistic Interpretability Workshop, 2025 paper |
|
Robust quadruped jumping via deep reinforcement learning
Guillaume Bellegarda*, Chuong Nguyen*, Quan Nguyen Robotics and Autonomous Systems, 2024 arXiv / paper / video |
|
|
Viability leads to the emergence of gait transitions in learning agile quadrupedal locomotion on challenging terrains
Milad Shafiee, Guillaume Bellegarda, Auke Ijspeert Nature Communications, 2024 arXiv / paper / project page |
|
|
Online optimization of central pattern generators for quadruped locomotion
Zewei Zhang, Guillaume Bellegarda, Milad Shafiee, Auke Ijspeert IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024 arXiv / paper / video |
|
|
Learning-based hierarchical control: Emulating the central nervous system for bio-inspired legged robot locomotion
Ge Sun, Milad Shafiee, Peizhuo Li, Guillaume Bellegarda, Auke Ijspeert, Guillaume Sartoretti IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024 arXiv / paper |
|
|
Dynamic object catching with quadruped robot front legs
André Schakkal, Guillaume Bellegarda, Auke Ijspeert IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024 arXiv / paper / video |
|
|
Learning human-robot handshaking preferences for quadruped robots
Alessandra Chappuis, Guillaume Bellegarda, Auke Ijspeert IEEE International Conference on Robot and Human Interactive Communication (ROMAN), 2024 arXiv / paper / video |
|
|
Visual CPG-RL: Learning central pattern generators for visually-guided quadruped locomotion
Guillaume Bellegarda, Milad Shafiee, Auke Ijspeert IEEE International Conference on Robotics and Automation (ICRA), 2024 arXiv / paper / video |
|
|
ManyQuadrupeds: Learning a single locomotion policy for diverse quadruped robots
Milad Shafiee, Guillaume Bellegarda, Auke Ijspeert IEEE International Conference on Robotics and Automation (ICRA), 2024 arXiv / paper / project page / video |
|
|
Quadruped-Frog: Rapid online optimization of continuous quadruped jumping
Guillaume Bellegarda, Milad Shafiee, Merih Ekin Özberk, Auke Ijspeert IEEE International Conference on Robotics and Automation (ICRA), 2024 arXiv / paper / video |
|
|
Identifying important sensory feedback for learning locomotion skills
Wanming Yu, Chuanyu Yang, Christopher McGreavy, Eleftherios Triantafyllidis, Guillaume Bellegarda, Milad Shafiee, Auke Jan Ijspeert, Zhibin Li Nature Machine Intelligence, 2023 arXiv / paper |
|
|
Puppeteer and marionette: Learning anticipatory quadrupedal locomotion based on interactions of a central pattern generator and supraspinal drive
Milad Shafiee, Guillaume Bellegarda, Auke Ijspeert IEEE International Conference on Robotics and Automation (ICRA), 2023 arXiv / paper / project page |
|
|
CPG-RL: Learning central pattern generators for quadruped locomotion
Guillaume Bellegarda, Auke Ijspeert IEEE Robotics and Automation Letters, 2022 arXiv / paper / video |
|
|
Robust high-speed running for quadruped robots via deep reinforcement learning
Guillaume Bellegarda, Yiyu Chen, Zhuochen Liu, Quan Nguyen IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022 arXiv / paper / video |
|
|
Dynamic vehicle drifting with nonlinear MPC and a fused kinematic-dynamic bicycle model
Guillaume Bellegarda, Quan Nguyen IEEE Control Systems Letters, 2021 paper / video |
|
|
An Online Training Method for Augmenting MPC with Deep Reinforcement Learning
Guillaume Bellegarda, Katie Byl IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2020 arXiv / paper / video |
|
|
Versatile trajectory optimization using a LCP wheel model for dynamic vehicle maneuvers
Guillaume Bellegarda, Katie Byl IEEE International Conference on Robotics and Automation (ICRA), 2020 paper / video |
|
|
Trajectory optimization for a wheel-legged system for dynamic maneuvers that allow for wheel slip
Guillaume Bellegarda, Katie Byl IEEE 58th Conference on Decision and Control (CDC), 2019 PDF / paper / video |
|
|
Training in task space to speed up and guide reinforcement learning
Guillaume Bellegarda, Katie Byl IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2019 arXiv / paper / video |
|
|
Design and Evaluation of Skating Motions for a Dexterous Quadruped
Guillaume Bellegarda, Kees van Teeffelen, Katie Byl IEEE International Conference on Robotics and Automation (ICRA), 2018 PDF / paper / video |
|
|
Nonintuitive Optima for Dynamic Locomotion: The Acrollbot
Guillaume Bellegarda, Nihar Talele, Katie Byl IEEE International Conference on Robotics and Automation (ICRA), 2018 paper / video |
|
|
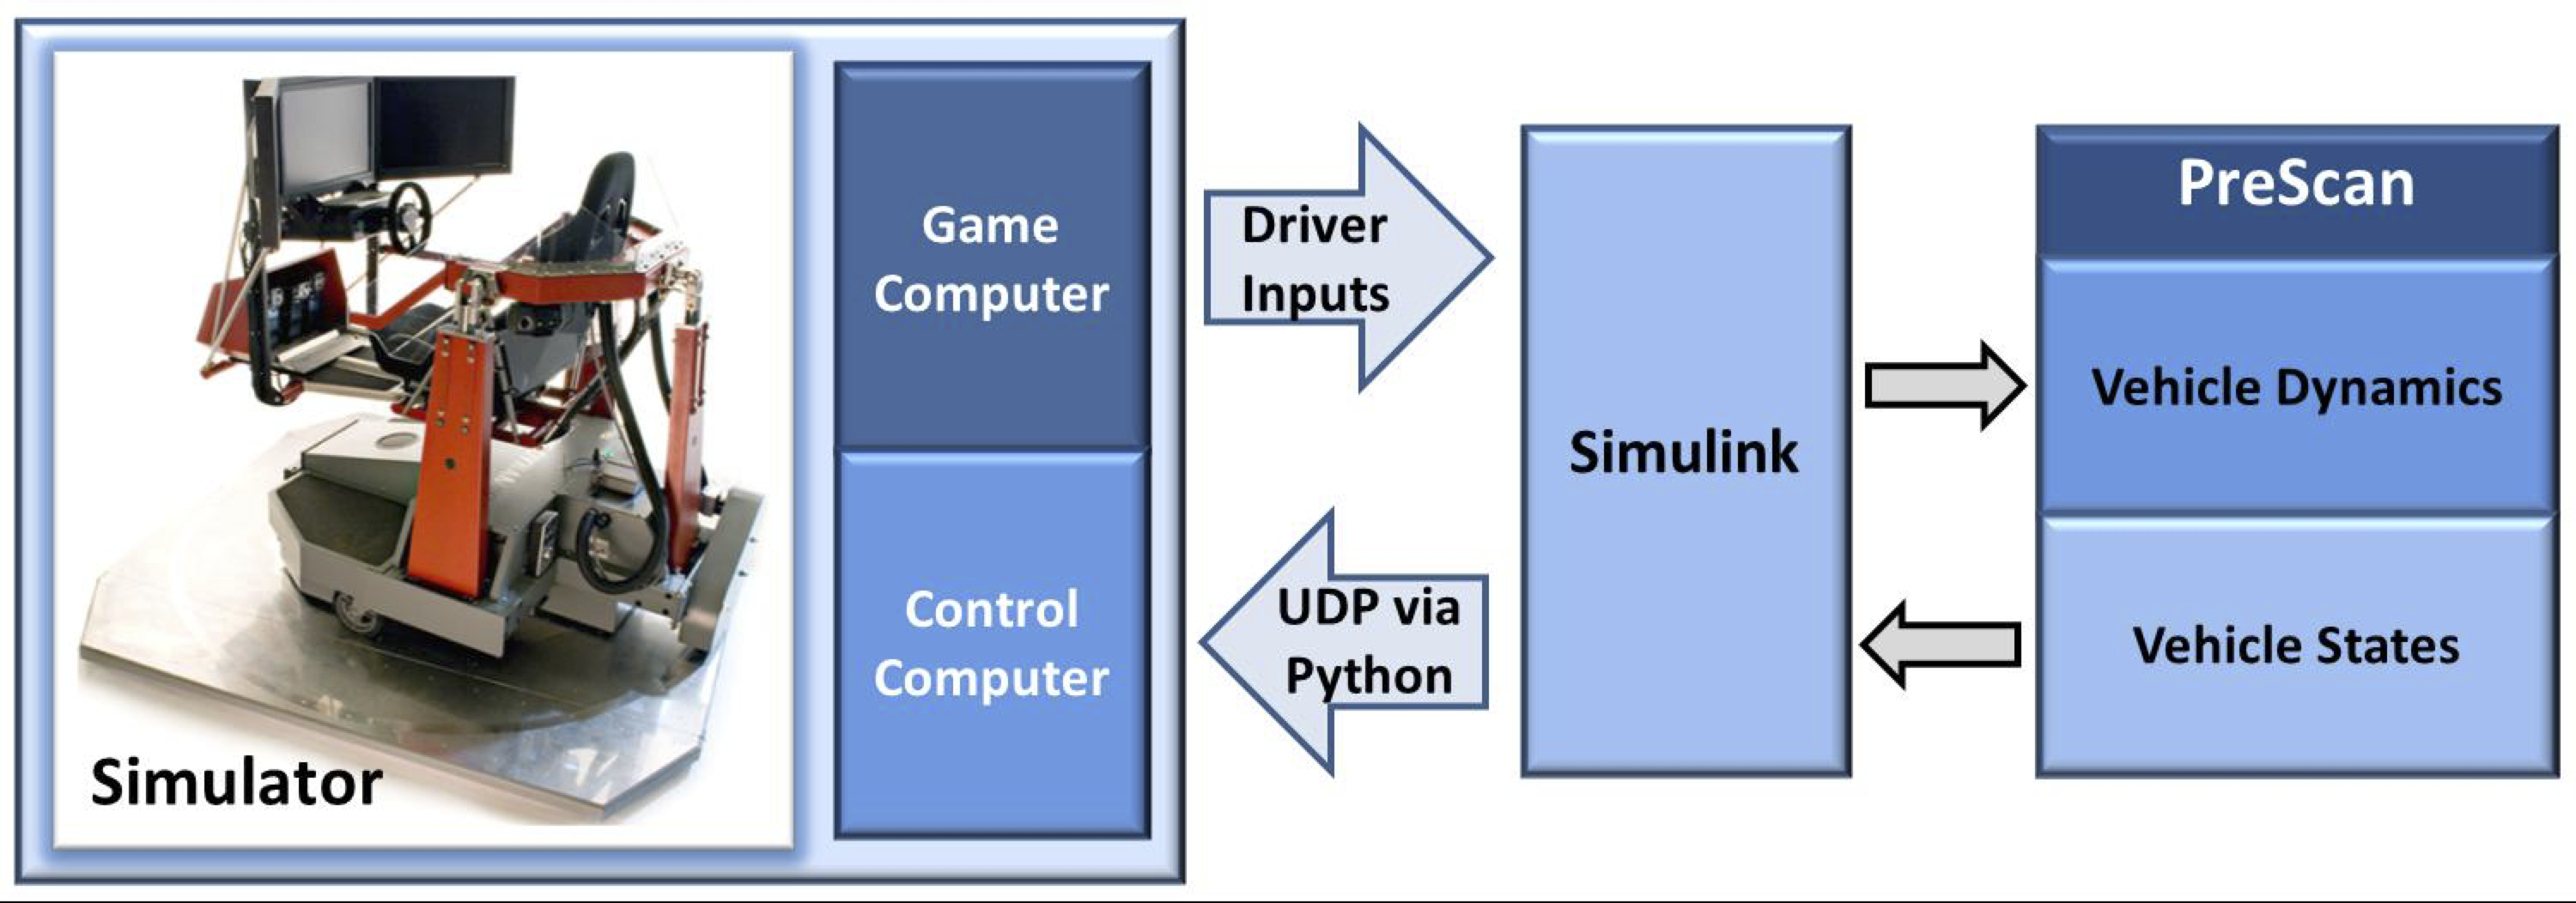
Experimental design for human-in-the-loop driving simulations
Katherine Driggs-Campbell, Guillaume Bellegarda, Victor Shia, S Shankar Sastry, Ruzena Bajcsy arXiv preprint arXiv:1401.5039, 2014 arXiv |
|
Website template from Jon Barron. |